

In this two-player co-op game, move around inside the robot to manually control each of the C-Pider’s claws and climb a mountain full of surprises.
Genre: Co-op, Climbing
Engine: Unreal Engine
Team size: 3 people
Duration: 10 weeks
Period: november 2025 - january 2026



Context
C-Pider was my first project using Unreal Engine at ISART Digital. The goal was to create a game with an original and innovative 3C concept. We created a sandbox environment to test and iterate on the 3Cs and various gameplay mechanics.
The game was designed and prototyped by a team of 3 Game Designers.


My roles
My role on the project was Technical Game Designer, focusing on the design of the 3Cs and game documentation.
In Unreal Engine, I prototyped part of the 3Cs and several gameplay mechanics using Blueprints. I also created the sandbox level used to test and iterate on the mechanics.
Screenshots
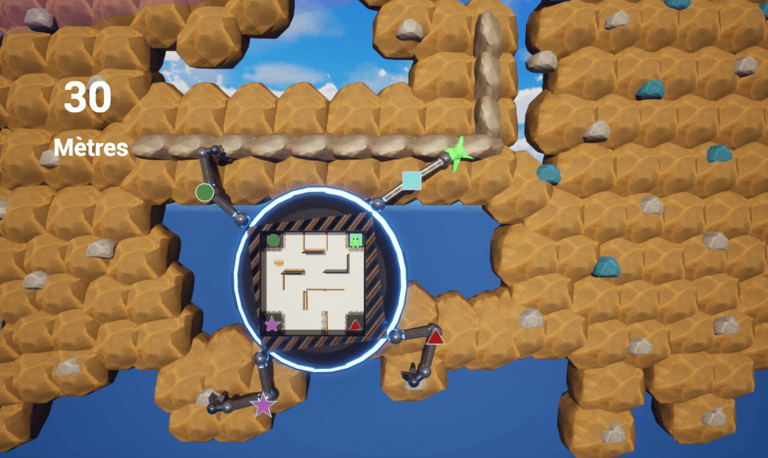
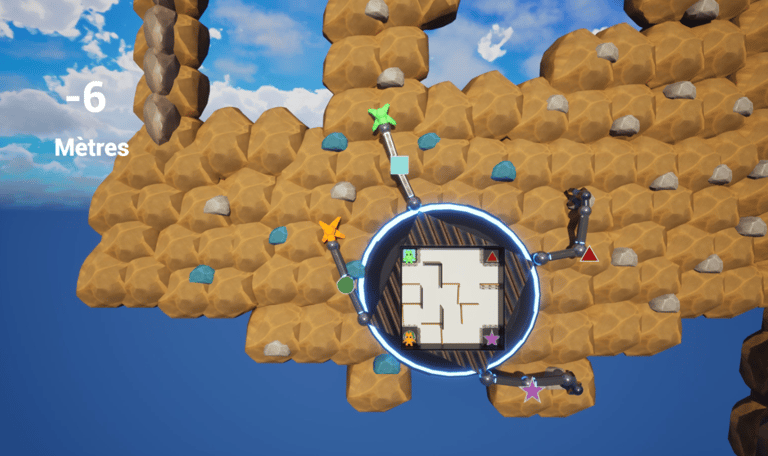
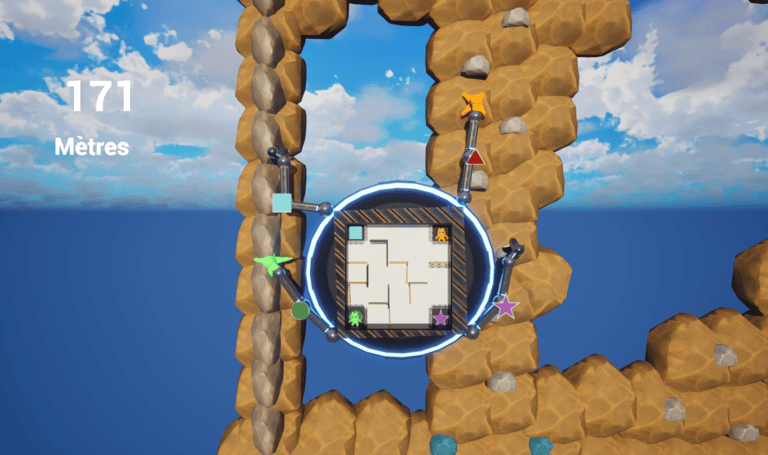
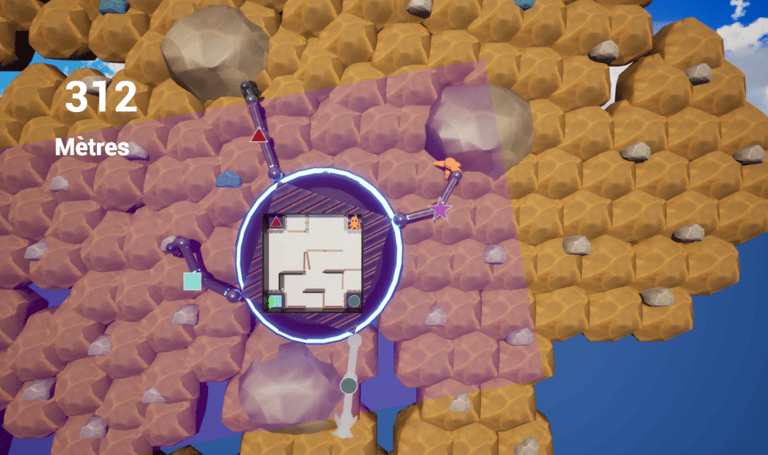
My Roles
Game Design


3Cs Design
I contributed to the game concept through several iterations.
With the team, we created a technical document detailing the game’s 3Cs (Camera, Character, Controls).
The main constraints were the limited time and the team’s technical skill. We encountered several design challenges throughout the project, and had to adapt our solutions to fit the constraints.


Prototyping


We programmed the game using Unreal Engine’s Blueprint. I contributed to the 3Cs by scripting:
Claw controls: I used the Physics Constraint system to handle the joints of the legs. For movement, I applied velocity forces to the claws.
Claw grabbing system: I created a weight system for attaching the claws to holds. A claw releases if it is the only one attached, and the claws force become stronger when multiple claws are attached.
Dynamic camera: I implemented a camera system that moves and zooms in/out based on the positions of the players and the claws they are controlling.


3Cs Scripting:
Features Scripting:
For the sandbox, I programmed several different features:
1) Standard Holds: These holds can be grabbed by a one claw.
2) Large Holds: These holds are larger and can be grabbed by multiple claws simultaneously.
3) Breakable Holds: These are ice holds that break after a time once a claw grabs onto them.
4) Three-Claw Zone: When C-Pider enters this area, one of its claws becomes disabled, limiting the robot to 3 controllable claws.
1
3
2
4
Blueprint Scripting:
Level Design


I created the blockout of the sandbox map dedicated to testing the 3Cs.
The goal was to create a non-linear map divided into several traversal sections, each introducing new features or ways of interacting with the environment.
For example, some areas require horizontal or vertical climbing, while others feature different types of holds, such as breakable or large holds. One area also includes a zone that temporarily disables one of the robot’s claws.
Walkthrough

Credits
Game Designers
Ralif TAZUTDINOV
Maxence RICHARD
Thibault ESTEVES